Ekaa.
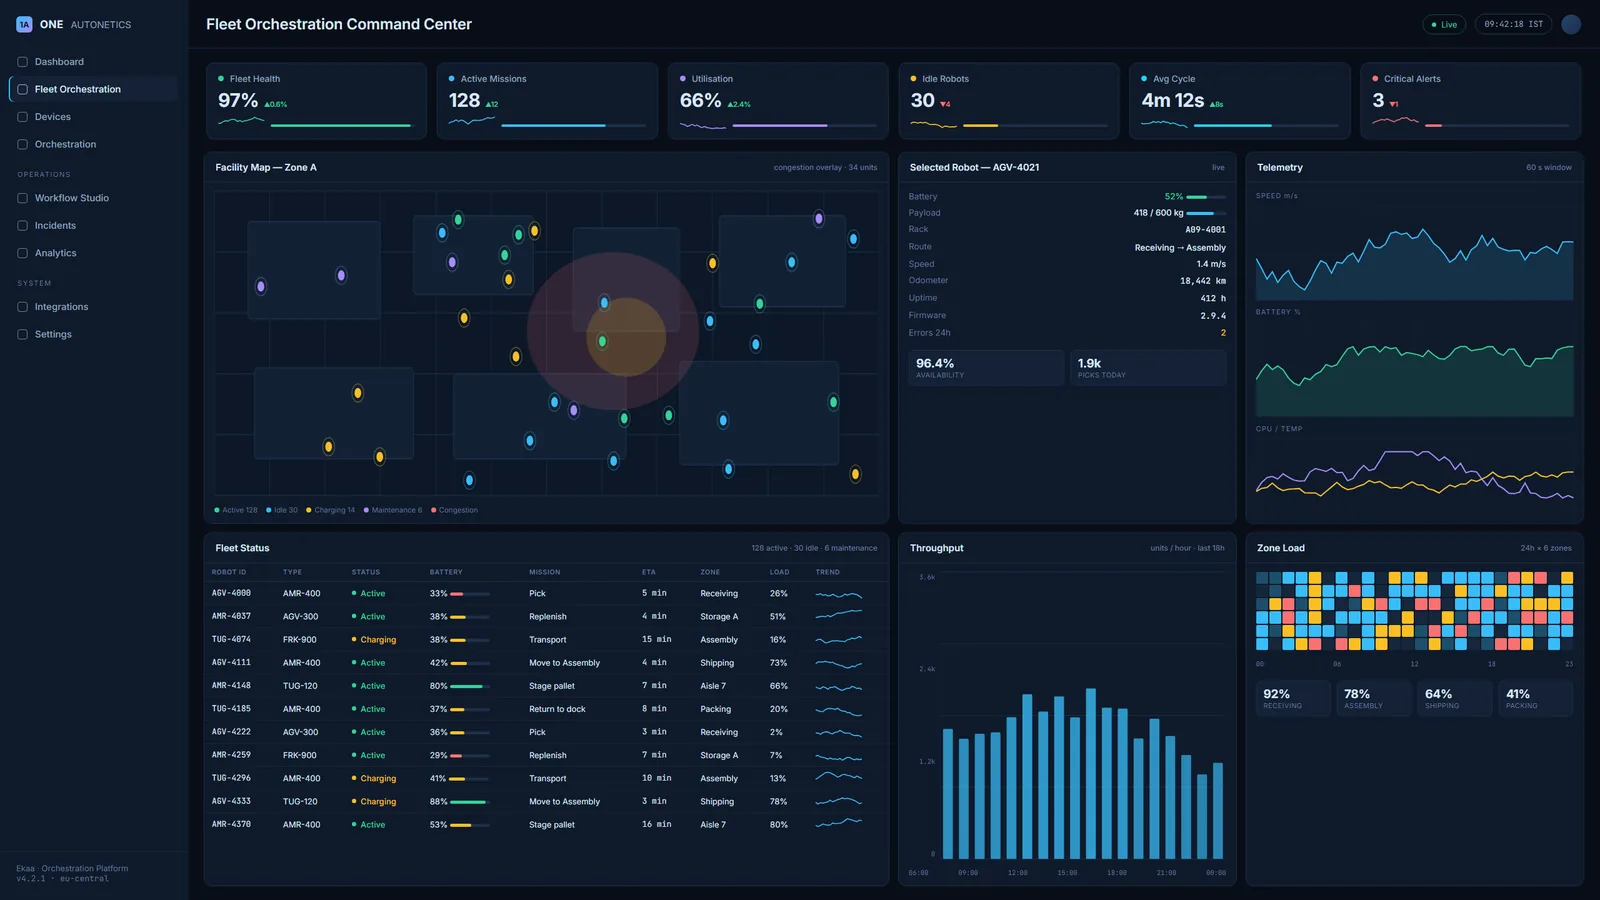
An orchestration platform for mixed robot fleets — one control surface for the AMRs, AGVs and cobots on a factory floor, and for the handful of people supervising them.
Scroll
An orchestration platform for mixed robot fleets — one control surface for the AMRs, AGVs and cobots on a factory floor, and for the handful of people supervising them.
A dark factory runs on machines from different manufacturers, each arriving with its own protocol, its own console and its own firmware cadence. Operations ends up watching four screens and fully trusting none of them. Ekaa's job is to make a fleet that is heterogeneous by procurement behave as one system by design.
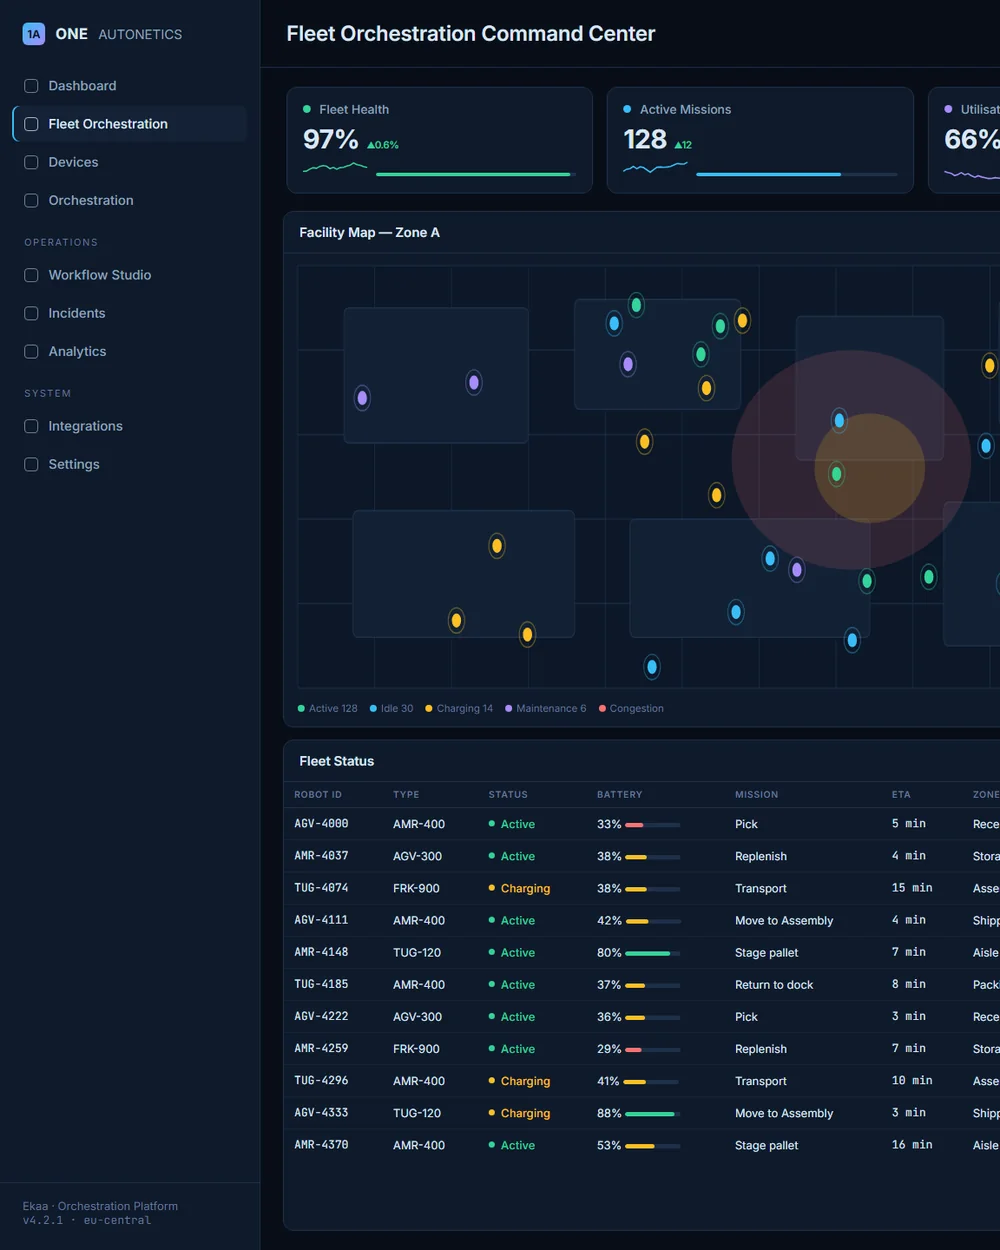
Underneath everything sits a device registry that normalises each make and model behind one interface, with protocol adapters — MQTT, gRPC, Kafka — beneath it. A mission is written once against capabilities rather than against a robot, so the fleet can be re-procured without rewriting the operation.
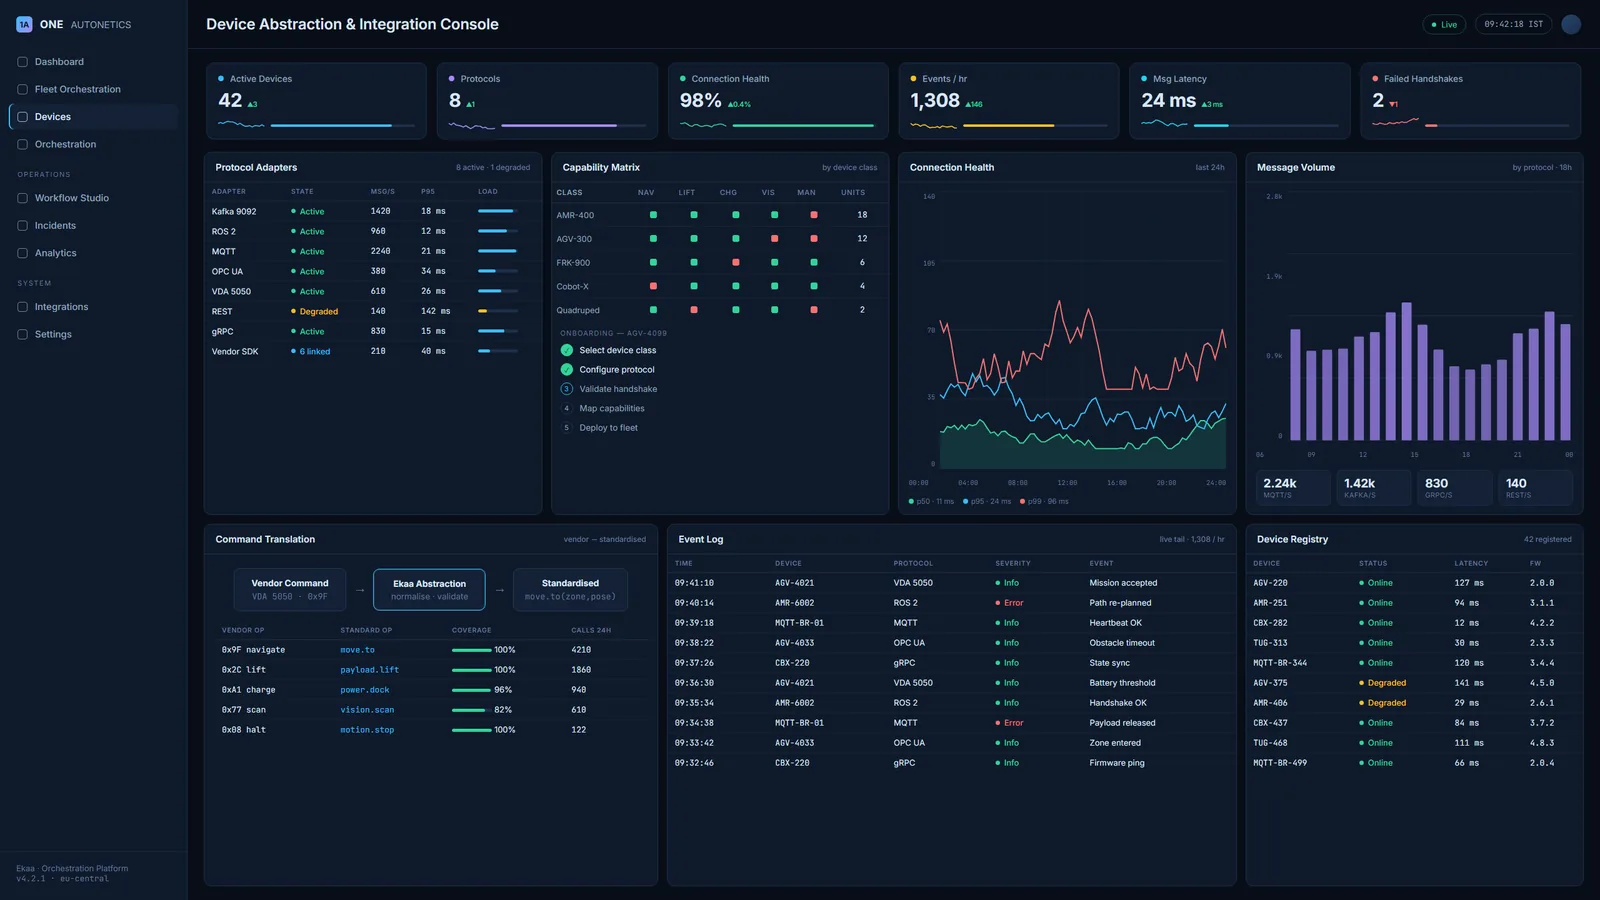
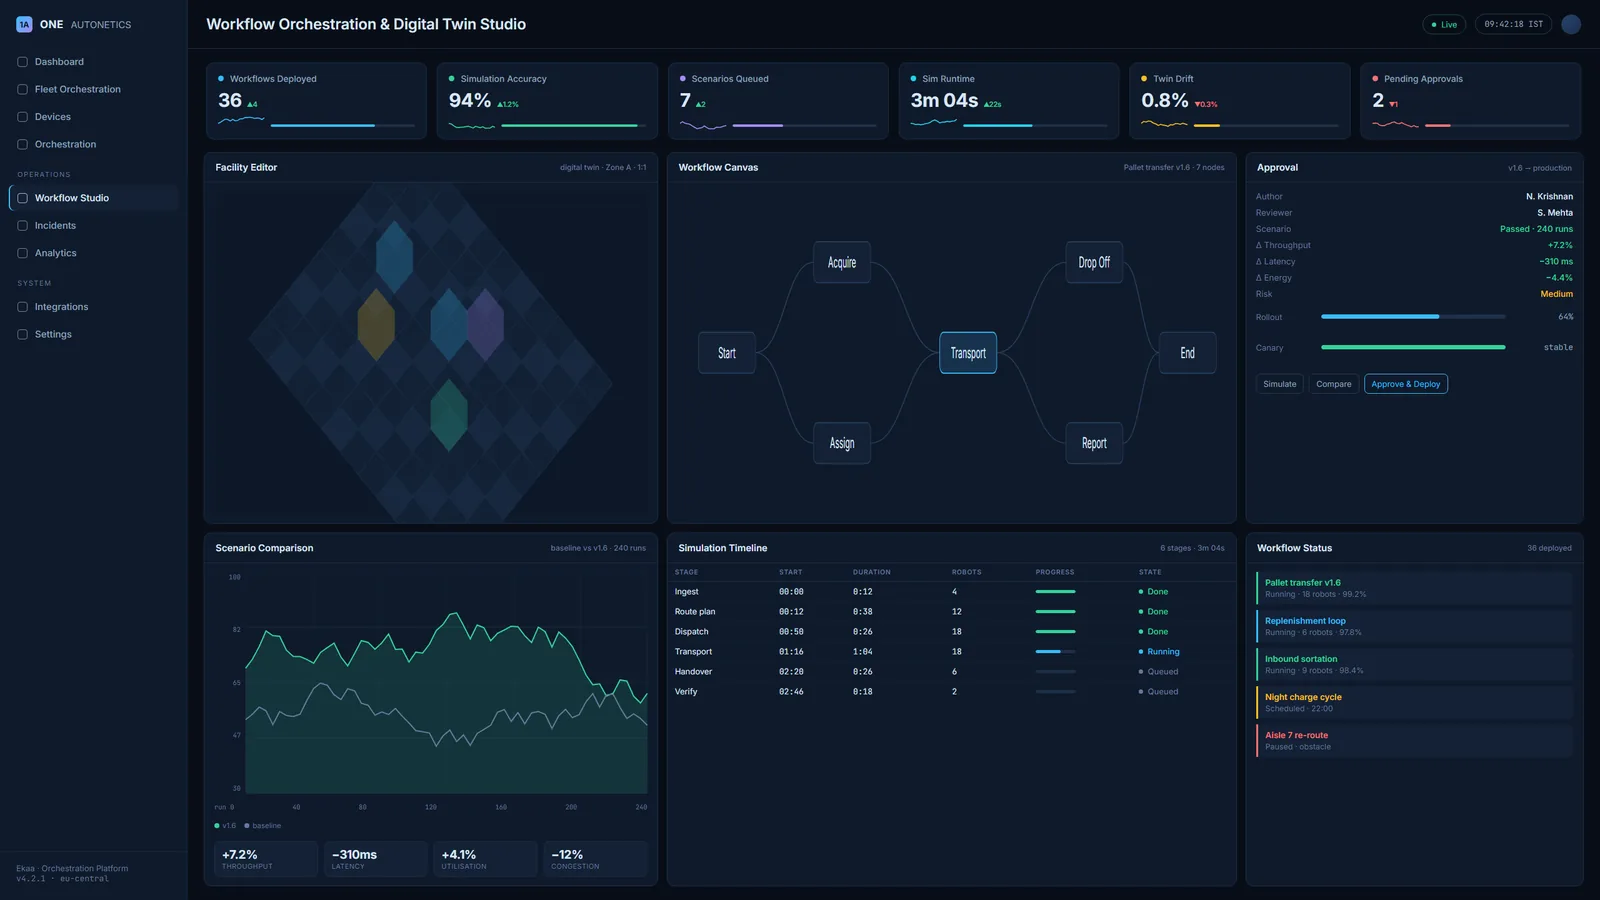
A command centre for live operations, a registry for device abstraction, a studio where a mission is simulated against a digital twin before it reaches a machine, and an observability layer for what actually happened. The studio is the load-bearing one: nothing goes to the fleet that has not been run against the twin first, and rollouts stage through a canary rather than landing everywhere at once.
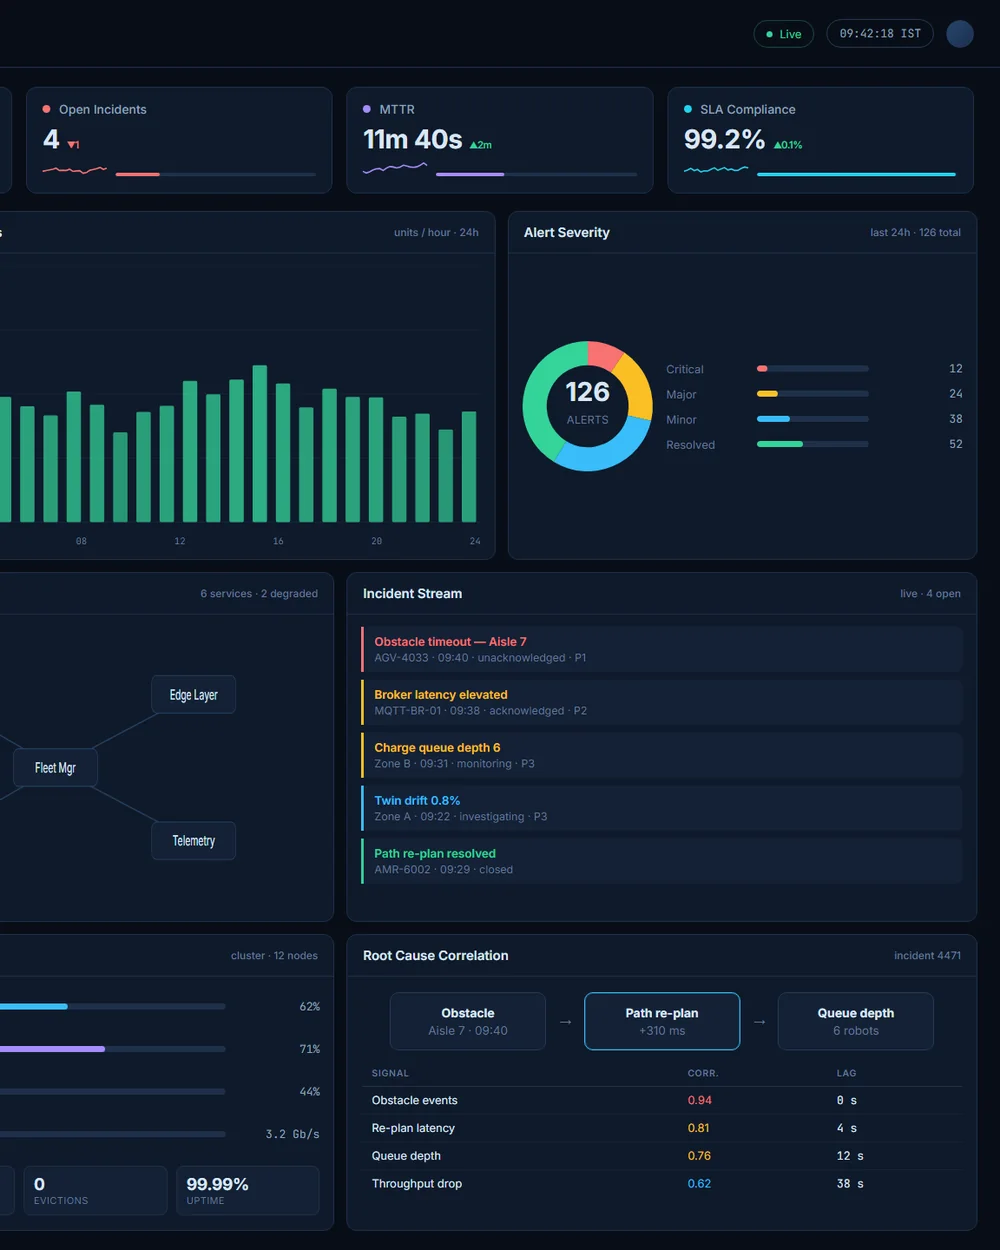
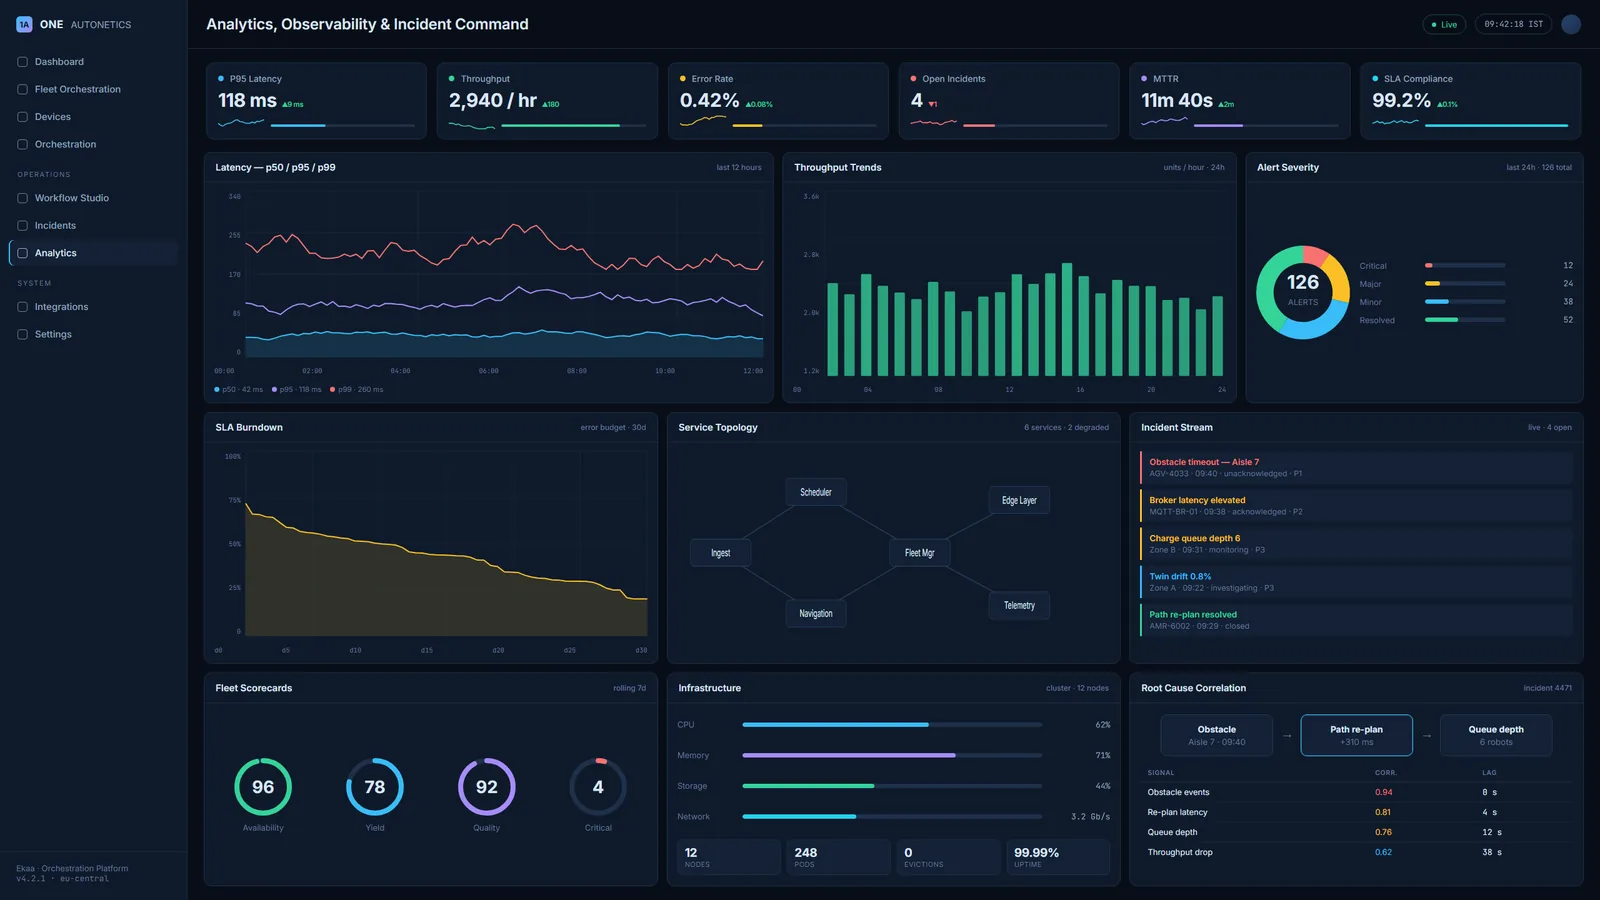
Interface figures shown are illustrative, not client operating data.